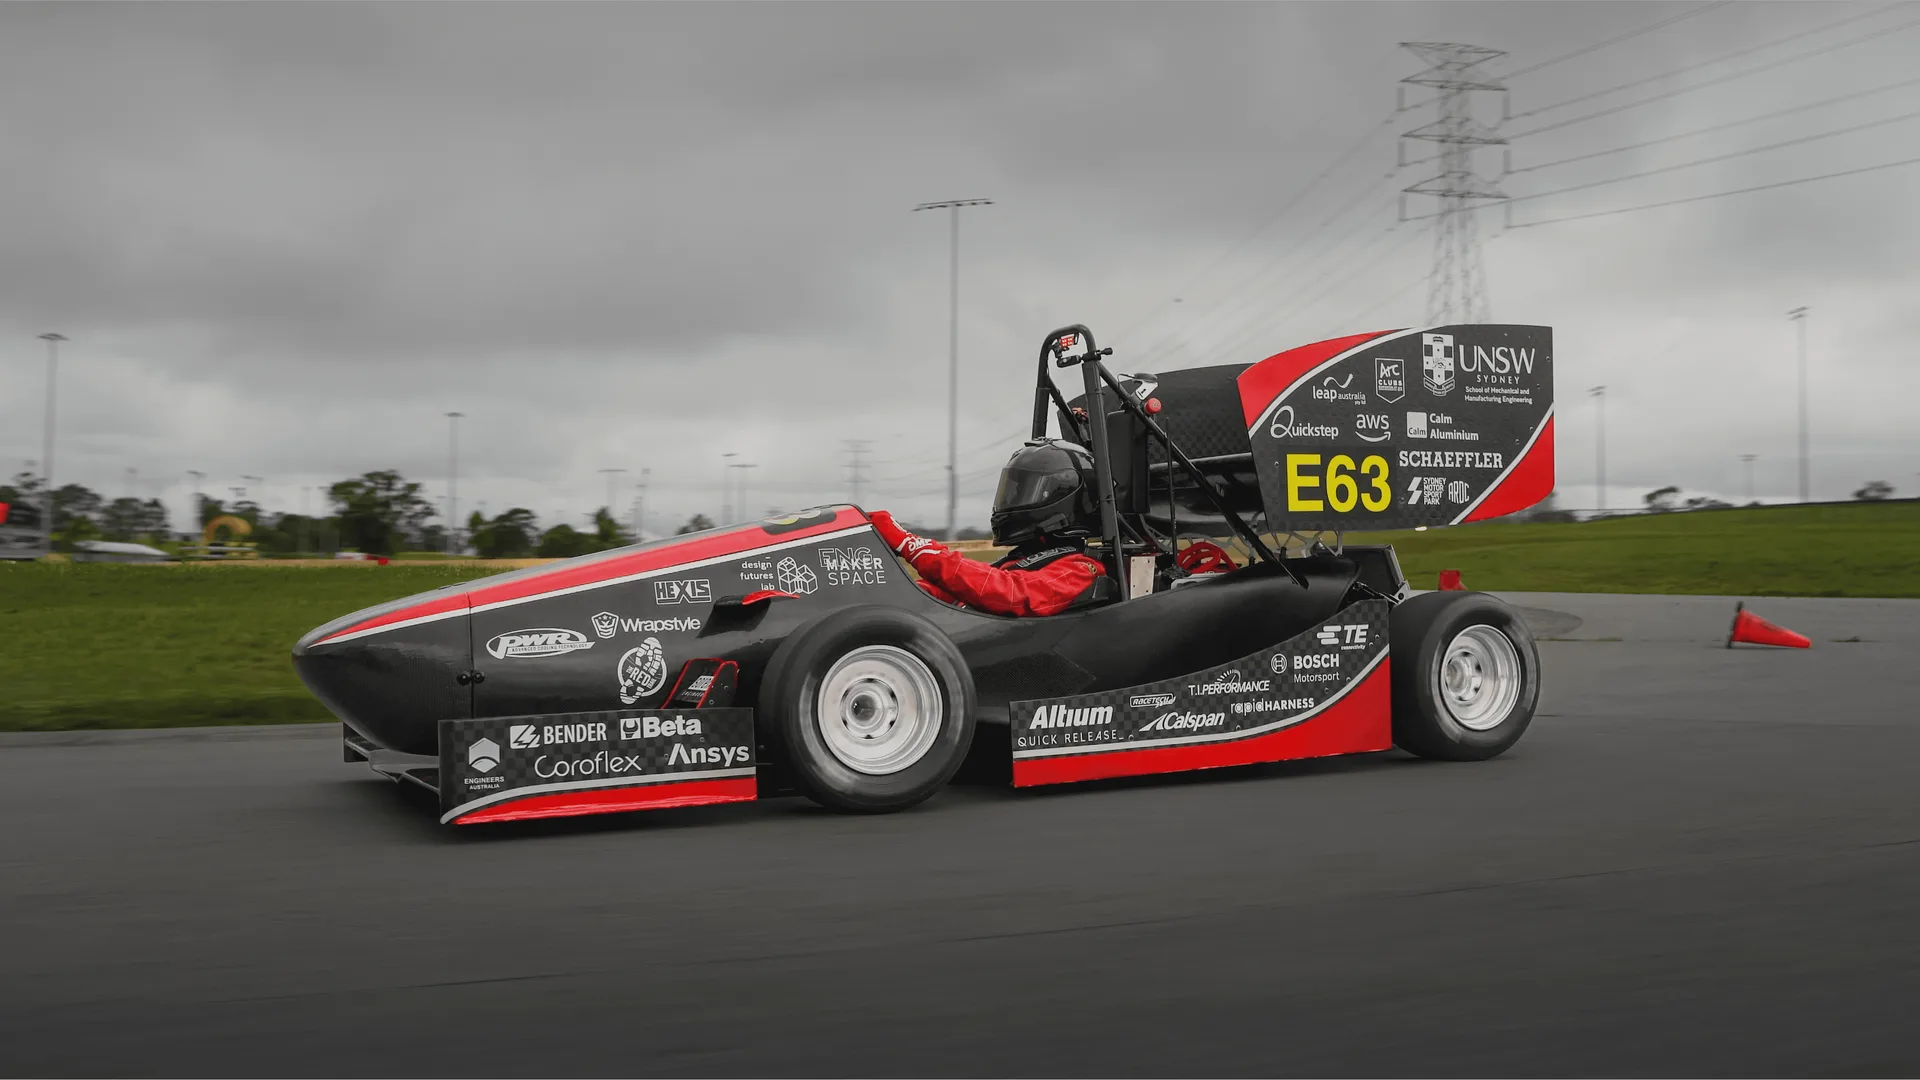
Autonomous Formula SAE – Redback Racing
Built real-time perception and autonomy systems for UNSW’s Formula SAE driverless race car using YOLOv7, ZED depth sensing, and NVIDIA Jetson compute.
Computer Vision & Perception Engineer
2021–2023
Overview
As part of UNSW Redback Racing’s autonomous team, I worked on the perception and autonomy stack for the Formula SAE driverless race car. My role focused on real-time object detection, sensor fusion, and integrating depth, vision, and LiDAR data into a reliable perception pipeline running on NVIDIA Jetson hardware.

Real-Time Perception on NVIDIA Jetson
I integrated a ZED stereo camera with an NVIDIA Jetson Orion to generate depth-aware detections in real time. This setup served as the backbone for cone detection—a core requirement for autonomous navigation on the FSAE track.
YOLOv7 for High-Speed Object Detection
Using PyTorch and YOLOv7, I implemented a real-time cone detection system optimized for low-latency inference on Jetson hardware. This involved dataset prep, model training, hyperparameter tuning, and edge deployment.
Sensor Fusion & Mapping
I completed onboarding and production tasks involving ROS2, Open3D, and LiDAR scan processing. This included converting raw depth + LiDAR data into map-ready formats and contributing to the perception stack used during drive tests.
Cloud Training & Deployment
I trained and deployed models using AWS cloud services, leveraging GPU-backed EC2 instances to speed up training cycles. This enabled rapid iteration on model improvements and validation before deploying to the Jetson.
Teamwork & Process
Worked within Agile sprints using JIRA and Notion, collaborating closely with autonomy, controls, and electrical subteams. Participated in debugging sessions, code reviews, and on-track testing days.
“Building perception systems for an autonomous race car pushed my understanding of real-time vision, sensor fusion, and robotics integration to a whole new level.”